Operating System for Physical Work
Scroll
The Worker Classes

An OS coordinating humans, retrofit robots, purpose-built robots, humanoid robots, AI agents, and wearables — across Construction Sites, Facilities Cleaning, Logistic Hubs & Mining Sites — from one intelligence layer.
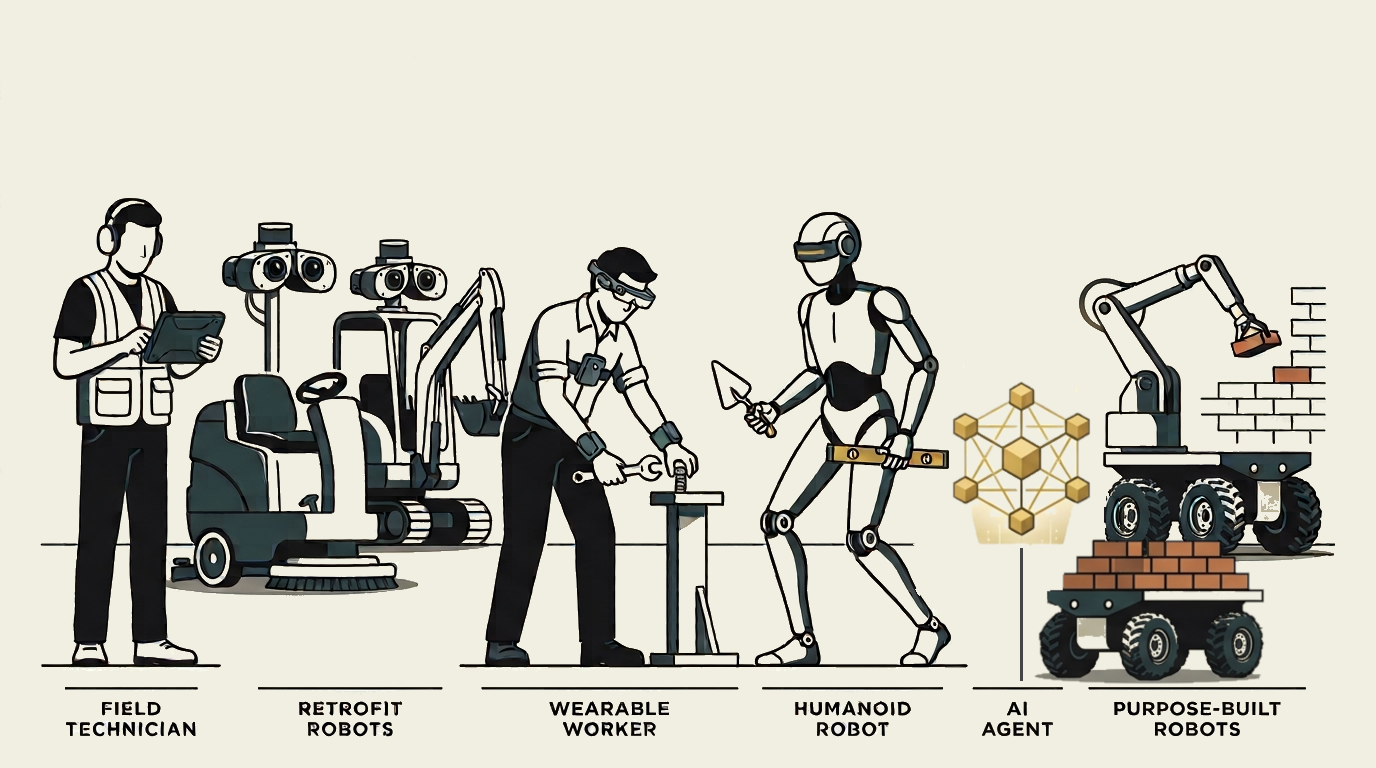
Pragma One coordinates six worker classes: a field technician, retrofit robots (a ride-on floor scrubber and tracked excavator with mounted camera and LiDAR pods), a wearable-equipped worker, a bipedal humanoid robot, an AI agent, and purpose-built construction robots (an AGV material tug and a bricklaying arm).
Operating System for Physical Work
The Operating System

Six modules describe what the OS does.

The modules explain what the OS does. The infrastructure shows how it runs.

See the full architecture
How it actually runs

The modules explain what the OS does.
The infrastructure shows how it runs.

Running at 60+ industrial sites, 24/7, since May 2023. Three years to build. Not a demo.
Layer 01 · Live Coordination
Coordination Channels + Live Dashboards
One coordination plane across every operational function. Every message, escalation, and resolution logged with timestamp. Live dashboards for every role, 24/7 — machine status, SLA, safety.
Real-time Channels
Role-Specific Coordination Groups
Field, network, site, specialist. Different scopes, one data plane.
Live Monitoring
Role-Calibrated Dashboards
Each role sees its scope. The intelligence layer sees all.
Layer 02 · Always-On Engines
Always-On Backend Engines
One engine behind every dashboard, across a heterogeneous fleet. Runs continuously. Emits data. Feeds the intelligence layer.
Engine 01
Predictive Maintenance
Machine health across 238+ types
Engine 02
SLA Management
Real-time reconciliation
Engine 03
Autonomous Navigation
Path planning · fleet routing
Engine 04
Operational Reports
Exception routing across the stack.
Layer 03 · Intelligence Layer
Real-to-Sim Enrichment Smiling Buddha
Every timestamped datapoint from Layers 01 and 02 flows in. Teleop is the highest-fidelity training signal. Annotation, CV, sensor fusion sit downstream — fed by production, not upstream of it.
Training Signal
Teleop → V1-V3 Anchor Data
Joint-level action data. Real production. SLA-graded.
R&D Downstream
Annotation · CV · Sensor Fusion
Fed by deployment. Not upstream of it.
Labs build models. Retrofit companies build kits. Robot companies build fleet dashboards. BRS Central AI built the delivery infrastructure.
brscentralai.com · smilingbuddha.co
Full Site Automation
Minimal manpower. Maximum automation.

Every deployed site captures data. Every capture reduces the next site's Human-in-Loop (HIL). That's the path to FSA.

Deployment Timeline
100% 66% 33% 0% Day 1 Month 1 Month 6 Month 12 FSA Autonomy % Human-in-Loop %
The curve is the mechanic. FSA is the outcome.
06 — Live Deployment

The OS isn't a roadmap. It's running today.

60+ sites. 238 machine types. 45+ OEM brands. Coordinated as one fleet by BRS Central AI — every day, in production, across enterprise customers.

Cleaning Fleet · One Operator · One OS
Scrubber · Sweeper · Dry Mop · Humanoid · High-Pressure Jet · Single Disc  —  six machine classes, one platform, one fleet.

Cleaning is live. Construction is next.
Same OS. Same coordination. New vertical.

Get in touch

The Operating System for Physical Work is running today.

60+ live sites. Our OS plugs intelligence on 238 OEM brands & 15,000+ embodiments. 18,000+ catalogued edge cases — open-sourced on smilingbuddha.co.
Subscribe for research and field notes.